HUD Calibration & Inspection System (Collaborative Robot Type)
Adas Calibration EquipmentUR10 collaborative robot with SONY industrial camera simulates human-eye viewpoints; automatic curtain blocks ambient light; SICK area scanners and ultrasonic glass detection for safety; fully automatic calibration by PLC + IPC
Product Details
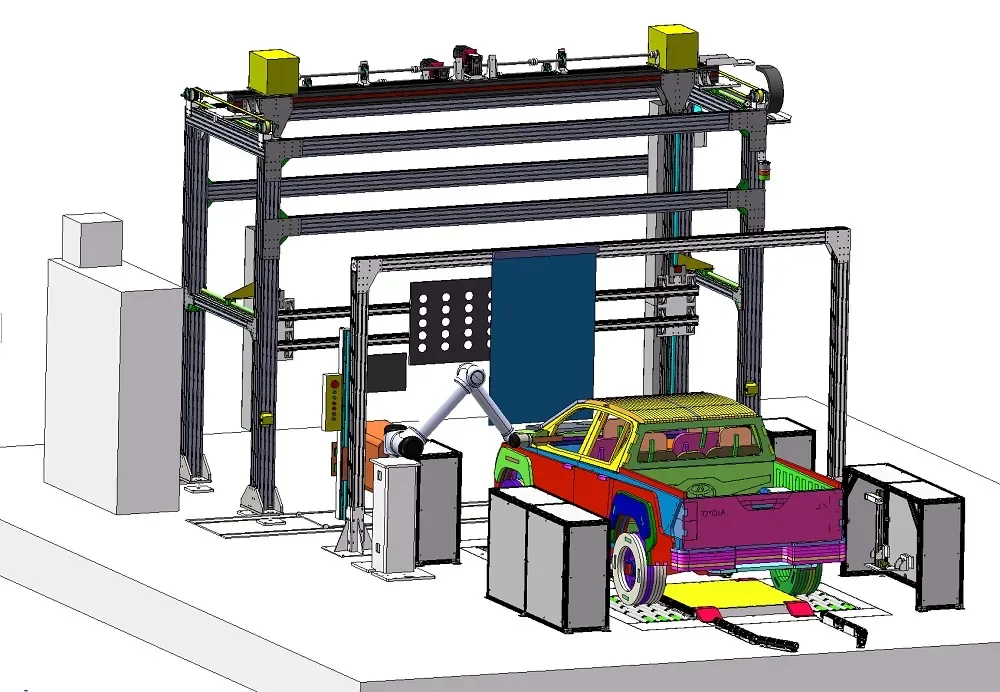
Driving assistance calibration equipment | Complete vehicle assembly offline HUD calibration station HUD calibration detection system (collaborative robot type) Six-axis collaborative robot (UR10) with Sony industrial camera to simulate human eye multi-position sampling; automatic curtain shading to eliminate environmental interference; binocular safety scanning + ultrasonic glass detection and other multiple protections;PLC + IPC automatic calibration calibration field 3D layout: the measured vehicle, the robot gantry lifting mechanism and the front automatic shading screen UR10 collaborative robot load 10kg, working radius 1300mm, repeat positioning accuracy ± 0.1mm ± 0.1° control accuracy The robot pitch and roll angle control accuracy ± 0.1°, the gimbal range ± 45° automatic shading screen gantry black curtain is automatically in place, and the ambient light interference is eliminated during calibration Product overview HUD calibration detection system is used for HUD (head-up display) calibration and inspection of the offline station of the final assembly of the vehicle to ensure that the position, clarity and field of view of the projected virtual image meet the design requirements of the vehicle.The system is a turnkey project: we are responsible for the overall design, manufacturing, pre-acceptance, packaging and transportation, installation, commissioning, training, paternity service, equipment transfer and final acceptance and after-sales service, and provide corresponding technical data.The equipment consists of a six-axis collaborative robot (UR10), PLC control cabinet (including IPC and measurement and control software), robot lifting mechanism, calibration device, camera and vision software, automatic shading screen, driver guide screen, regional safety scanner, T-SCAN Ⅱ communication instrument software development, MES network development, calibration program and data processing system.Measurement principle: On the main driver side, the manipulator with a camera moves under program control, and the industrial camera is placed in the driver's eye position for image capture; during the whole calibration process, the manipulator controls the camera to move multiple positions, and then the camera grabs the image by adjusting the Y/Z deflection angle. The amount of movement and the deflection angle at each position are determined by the HUD light system parameters: the imaging distance corresponds to the X-direction distance between the HUD information and the human eye;The viewing range angle and the size are the imaging viewing range formed by the HUD projection after multiple reflections/refractions; the visual range is the maximum range that the standard human eye can see at this distance; the vertical limit of the eye range defines the camera's Z-movement range; the vertical/horizontal deflection angle defines the basic reference value of the camera's deflection angle, and the camera deflects according to this angle when calibrating the edge image to simulate the eyeball deflection of the human eye at this position.During the calibration process, the automatic screen automatically walks to the front shading position, eliminating the interference of the front ambient light to the camera system, so that the imaging quality is stable and controllable.■ Fully automatic calibration of core advantages: The six-axis collaborative robot is used to automatically move the camera to each sampling position without the need for operator assistance; the robot automatically moves away from the driver's position when it is not working, making it convenient for the driver to get on and off.■ UR10 collaborative robot: load 10kg, working radius 1300mm, repeat positioning accuracy ± 0.1mm, to meet the position consistency requirements of camera and gimbal mounting and continuous operation for a long time. High■ camera positioning accuracy: The robot control accuracy reaches ± 0.1° downward (pitch) angle and ± 0.1° horizontal (roll) angle, providing a stable reference for virtual image position and distortion evaluation.■ Adaptive gimbal: The camera system consists of an automatically adjustable gimbal and an industrial camera with a lens. The gimbal can rotate around the X-axis and the Y-axis. The downward (pitch) angle is ± 45°, and the horizontal (roll) angle is ± 45°. It can not only adapt to different models, but also compensate for the body posture difference caused by inconsistent left and right tire pressures.■ Industrial-grade PoE cameras: Sony industrial Ethernet PoE cameras are used to adapt to the large-scale production environment on industrial sites; the lens focal length can be negotiated and determined according to the requirements of HUD manufacturers.■ Automatic shading screen: gantry type opaque black cloth curtain, automatic shading in place when calibrated, shading area X ± 1000mm, Z 300 ~ 1800mm, variable frequency motor drive, eliminate ambient light interference from the source.■ PLC + IPC integrated control: The control cabinet integrates the main switch, operation button, control power supply, actuator, control circuit, emergency stop circuit, PLC, IPC, local display, UPS and traffic lights; the temperature in the cabinet exceeds 32 ℃ and automatically starts the air conditioner to maintain the constant temperature in the cabinet.■ Measurement and control software TYX hudsystem: configurable modular design, supports custom test sequences, modifies test files, accesses all sensor and actuator data, and can be freely accessed between different test bench systems; based on Visual Studio 2017/C + + development, it can run on Windows 7/8 .1/10 Professional and above. Networking■ with MES: The MES system is networked according to the user networking protocol to realize the interconnection between the test data and the production system.■ Multiple safety protection: buzzer and three-color light prompt warning, sick high-altitude and low-altitude area scanning, ultrasonic sensor detection glass, vibration sensor detection touch obstacle, manual confirmation of key device personnel disembarkation and glass descent; safety strategy press "before the operation personnel leave the vehicle/glass descent and press the key to confirm the → movement before scanning the high-altitude position to → rise and fall into place after scanning the low-altitude position to → confirm the safety after the robot moves to the working position" to execute, when the scanning is dangerous, the warning prompt.■ Perfect delivery and service: turnkey project delivery, including installation, commissioning, training, and accompaniment; warranty period of 24 months, response within 4 hours of failure within the warranty period, and dispatching personnel to the site within 12 hours if necessary; 4 hours of response outside the warranty period, on-site at the latest 24 hours, responsible for after-sales service and ensuring the supply of spare parts and wearing parts.Structure and details Robot operation position diagram: Collaborative robot with camera sampling on the main driver side, safety scanning sensor set up in the work area Automatic screen: gantry type opaque black curtain door, automatic walking to the front shading position when calibrated PLC control cabinet: integrated PLC, IPC, local display, UPS, traffic lights and cabinet air conditioner (Rittal, IP51) imaging capture diagram: camera at different positions by pitching and rolling deflection angle simulating human eye observation HUD virtual image HUD virtual image evaluation parameter table (inGerman control): position, rotation, tilt, trapezoidal distortion, straightness and clarity and other bench structure diagram: calibration station machinery and basic layout of the main technical parameters of the equipment to form a collaborative robot (UR10), PLC control cabinet, robot lifting mechanism, calibration device, camera and vision software, automatic screen, driver guidance screen, regional safety scanner (sick), T-SCAN II communication instrument software development, MES network development, calibration procedures, data processing system and random accessories and spare partsCooperative robot UR10 (UR10): load 10kg, working radius 1300mm, repeat positioning accuracy ± 0.1mm, 6 rotary joint manipulator control accuracy downward (pitch) angle ± 0.1°; horizontal (roll) angle ± 0.1° gimbal rotation range downward (pitch) angle ± 45°; horizontal (roll) angle ± 45° (model GG-AR60) industrial camera Sony Mako G-131B, CMOS, GigE interface, PoE power supply, image size 1600 × 1200;The lens focal length is negotiated with the HUD manufacturer to determine the automatic curtain gantry left and right switch opaque black curtain door; shading area X ± 1000mm, Z 300 ~ 1800mm; frequency conversion motor drive (Siemens motor and driver) PLCSiemens S7-1500 series (CPU 6ES7511-1AK02-0AB0), programming software TIA Portal I/O and network Siemens I/O and interface module (IP20); Ethernet switch 6GK5008-0BA00-1AB2; terminal WAGO touch screen Siemens 6AV2124-0MC01-0AX0 industrial computer (IPC) Advantech IPC-610MB;CPU Core i5/i7; memory 16GB; hard disk ≥ 500GB; operating system Windows 7 Pro/SP1; 3 × 10/100/1000 Base TX LAN; 6 × RS232C, 1 × Parallel, 2 × USB2.0, 1 × VGA; PCI/PCIe ≥ 2 cabinet door display 17 ″ TFT cabinet door installation, best resolution 1024 × 768, Chinese interface, display fault diagnosis process prompt, test process parameters, test results, calibration parameters, etc. Control power input 100–240VAC 50/60Hz; output 24VDC 5A 120W (ABL8 REM24050/Schneider) UPS online;Input 115-300VAC 50Hz; Output 220 ± 2% VAC; Capacity 1kVA/800W; Fully loaded backup time > 5 minutes; Dimensions 145 × 220 × 355mm Control cabinet size H1800 × D600 × W1600mm (width adjusted as appropriate); Protection class IP51; Front/Rear door opening; Back plate galvanized; Surface spraying; Color RAL 7035; Air conditioner Rittal 1194420 in the production plant Rittal cabinet; Input power 1200W; Cooling power 700W; With condensate evaporation device, no water dripping;The cabinet temperature exceeds 32 °C to automatically start the three-color traffic light led; input 24VDC 0.5A; diameter 56mm; green = equipment standby access, yellow = calibration/testing, red = warning/fault (TL56-302-DC24V/Talent); Pilz PNOZ s3/PNOZ s7 installed in the top safety relay of the control cabinet entrance direction Servo drive Siemens 6SL3210-5FB10-2UF2; servo motor 1LF6 series; linear module high engineer HK210/TH8/TH14 series driver guide screen 32 ″ TFT (LG V719);Suspended or upright mounting; Optimal resolution 1024 × 768; Display calibration process and results, operation information and prompt information; Simplified Chinese; Connection cable 20m; Display height 400-1600mm (upright)/2000mm (suspended) Driver operation panel suspended or ground mounted; Barcode gun LS2208 (Symbol) 1 set, cable 15m; OBD-II-DLC connector 1 set (standard 16-pin SAE J1962), cable 15m;Emergency stop button 1 set (red mushroom head φ60mm, Schneider), cable 15m communication adapter EcuLinker/4.0: supports J1850 PWM/VPW, ISO9141-2, ISO14230 (5 baud init/fast init), ISO15765 (11/29bit, 500k/250k), J1939, can_USER1/2, ALDL160/8192, KWP1281 KKL, can TP2.0 etc protocol measurement and control software TYX hudsystem (Automation Unisystem executable module): modular configurable, supports custom test sequences, modification of test files, access to all sensor and actuator data, cross-test bench system access; development environment Visual Studio 2017/C + +/MFC 2017 security configuration buzzer and tricolor light prompt warning; sick high-altitude position scanning; sick low-altitude position scanning; ultrasonic sensor (glass detection); vibration sensor (touch obstacle detection);Key device (manual confirmation of personnel disembarkation and glass descent) Random documents and spare parts Random documents (Chinese/English/Korean); 1 spare PC; random spare parts and special accessories, random tools Warranty and service Warranty period 24 months from the date of final acceptance Qualified signature; emergency response within 4 hours within the warranty period Failure to resolve personnel to the scene within 12 hours;4 hours response outside the warranty period, 24 hours at the latest on-site, responsible for after-sales service for life, and ensure that spare parts and wearing parts supply training and paternity training for 5 days, 8 hours a day, up to 20 people/period, covering mechanical systems, control systems, maintenance, equipment calibration, parameter editing, programmable device use, etc.;3 days of accompaniment after equipment installation and commissioning training, 1 mechanical and electrical engineer per shift, 2 shifts corresponding to technical data 3 paper files, 3 sets of U disk electronic data: parts BOM list, electrical schematic diagram, hardware drawings, latest software backup, PLC program backup, training manual, equipment structure and working principle, operation essentials, maintenance essentials, parameter setting method, fault judgment and treatment method, etc. Calibration process Equipment standby: three-color light display green, the vehicle canDrive in. Vehicle enters and completes alignment. The front glass window descends and the driver exits the vehicle and confirms (manual confirmation by pressing the key device). Connect the OBD plug, scan the Vin code and press the start button. After the robot lifting mechanism and safety scan confirm that it is safe, the robot hand moves to the working position with the camera. The camera samples one by one according to the preset position and deflection: image shooting → → distortion detection distortion correction; automatic curtain shading during calibration.After the calibration is completed, return the aligner to the position and unplug the OBD plug. The driver gets in, the vehicle exits, and enters the next vehicle. Contact Us Beijing Taiyuanxiang Technology Co., Ltd. Tel: 010-89780650 Mobile: 18611929790 (Li Yongpo) Email: liyongpo @ taiyuanxiang.cn Address: Room 3027, Building 1, No. 10, Hongfu Yard, Beiqijia Town, Changping District, Beijing Service Content: Scheme design and basic funding, equipment manufacturing and integration, transportation installation and commissioning, operation training, acceptance support, after-sales maintenance and spare parts supply Note: The parameters and pictures on this page are arranged from the product technical solution, and are used only for product introduction;The size, configuration and technical parameters of the equipment can be customized according to the user's model and production line requirements, and any updates are subject to the contract and technical agreement without notice.
Related Products
View All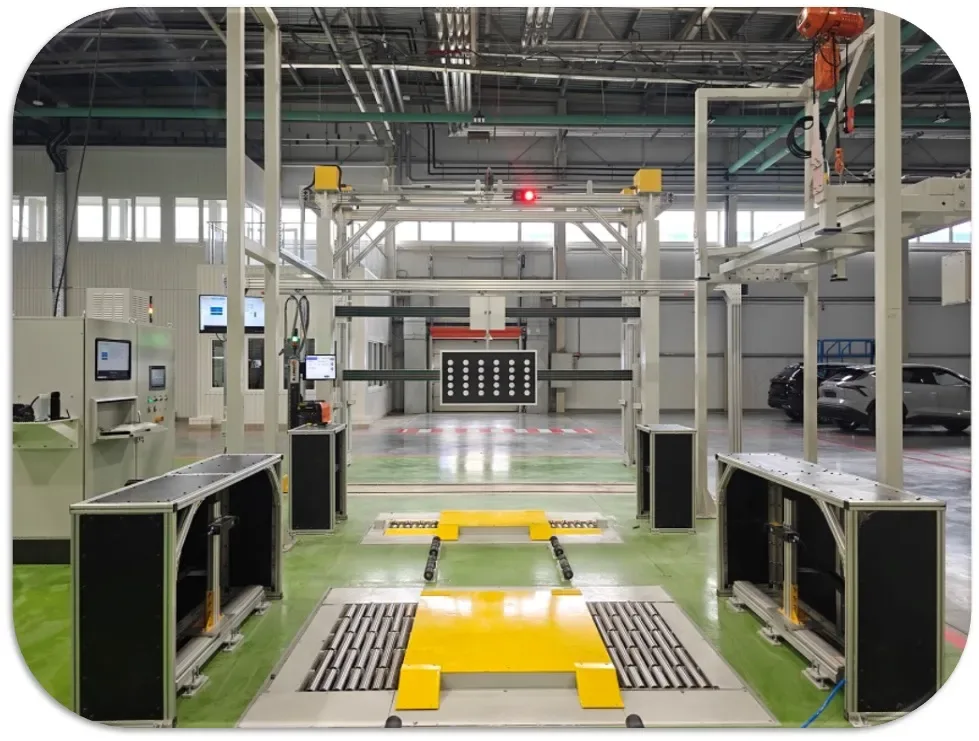
Wheel Arch Height Measuring Device
The front eyebrow height measurement sensor (2D camera) sensor uses a laser to measure based on the triangle principle. The position of the linear laser in the sensor and the angle with the camera are fixed after being calibrated. The 635nm red laser irradiates vertically to the highest point of the eyebrow on the front axis plane. After the 2D camera is imaged and identified in the CCD, the software solves the laser line to calculate the turning point, and solves the Y and Z coordinates of the corner point according to the laser triangle principle, where the Z coordinate is the height of the eyebrow.
Learn More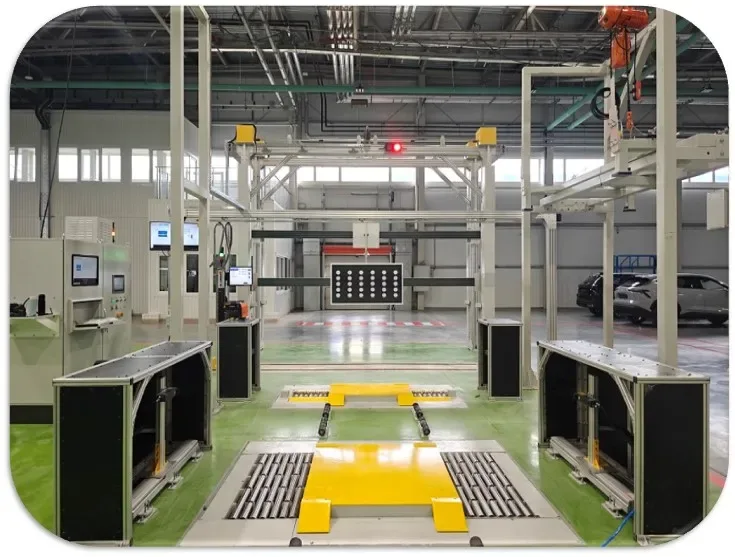
Integrated ADAS Station Calibration Frame
Aluminum integrated frame for zero-point verification
Learn More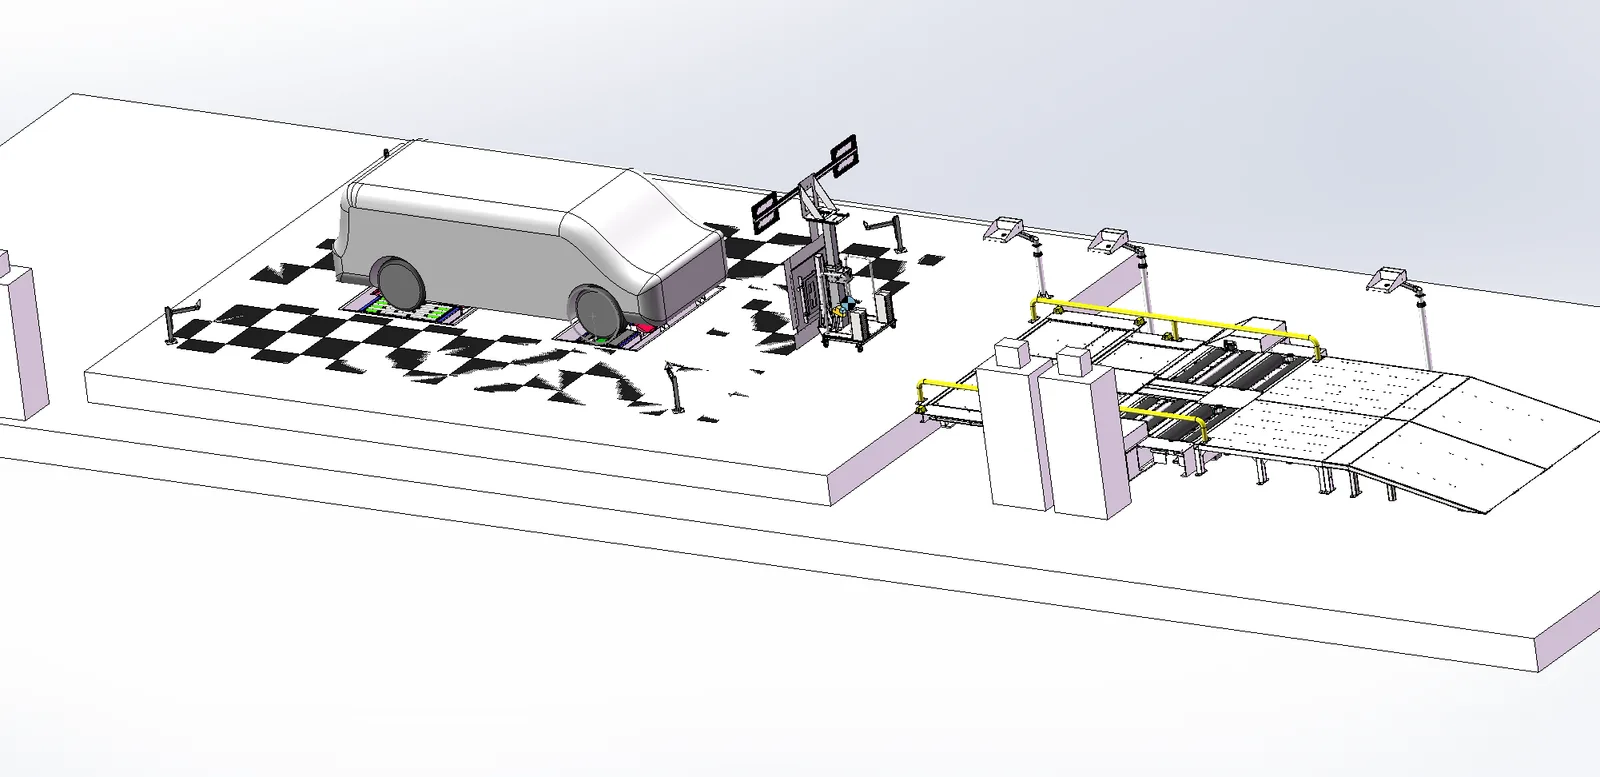
Simplified ADAS Calibration Equipment
Calibration equipment for LDW cameras, AEBS/FCW front radar (reflector type), BSD corner radar and AVM surround-view cameras. LDW height 1500-1700mm, AEBS height 500-800mm, worm-turbine-gear-rack two-stage synchronous lift, wheeled target trolley with locating pins, wireless Bluetooth OBD module and calibration/flashing software.
Learn More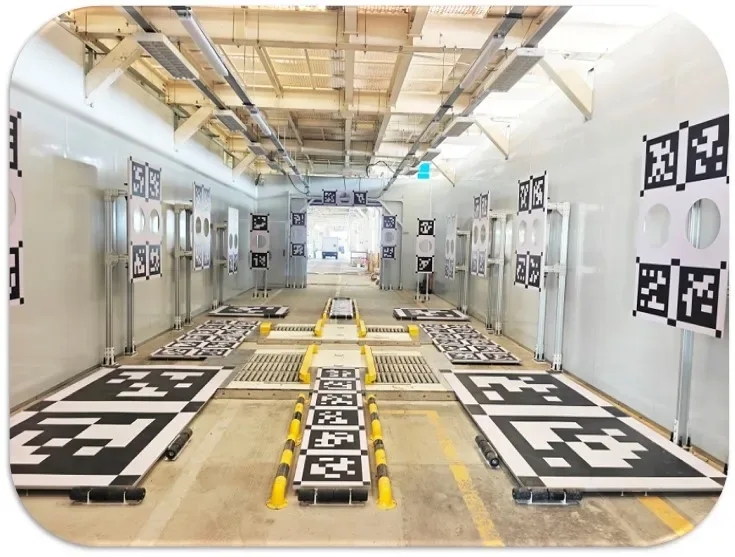
Autonomous Vehicle Calibration Room
Full-vehicle sensor calibration room with automated target workflow
Learn More